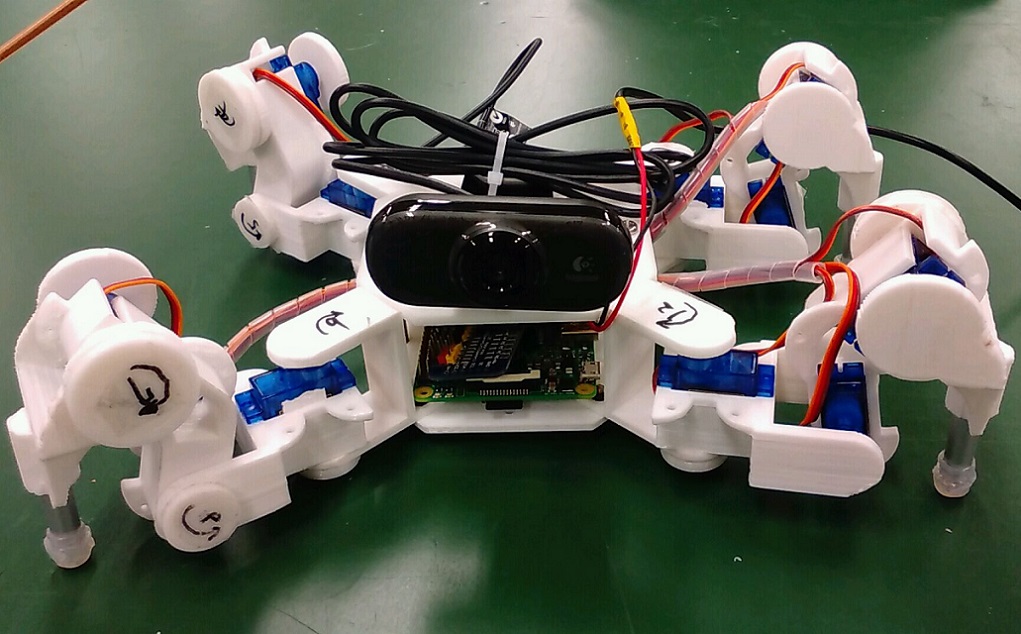
saturn
S.E.I.M. Multiple Legs
With external devices, Single-robot
L:250mm * W:300mm * H:100mm, 0.6kg, 25mm/s
Vision sensor,
Appeals:
多脚です.カメラに挑戦してみました.
Characteristics:
移動はそれぞれ3つのサーボからなる4本の足で行います。取り付けられたカメラの情報をraspberry piで処理をしボールを判別します。
Results
1st Pre.round Game: 0.00, Judge: ---, Compensation: 0, Sum.:0.00
Performance: --- Challenge: --- Art:--- Speed :---